01 / CUSTOM ELECTRONICS
A six-layer control board.
Six actuators, sensor inputs, ESP32 control and battery management, brought together on a custom board.
View the project overviewLimited public overview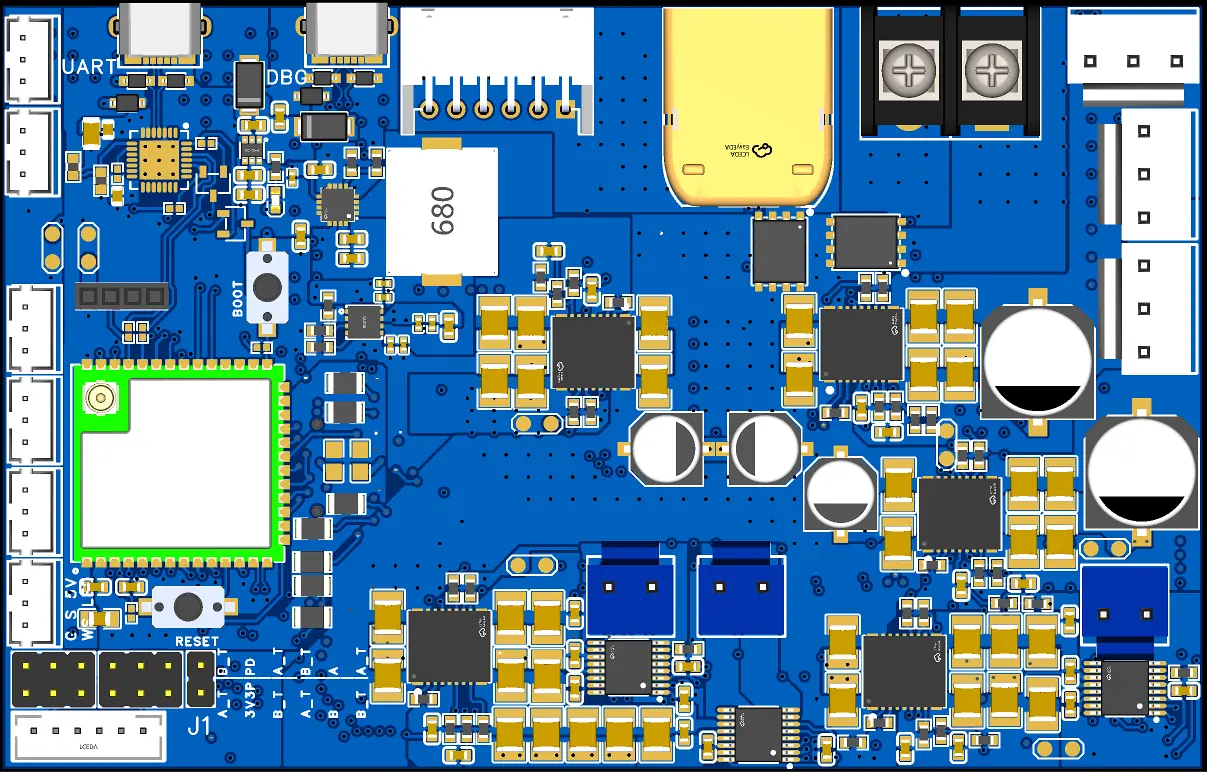
Engineering work
Custom boards, embedded software and connected devices. Review the requirements, implementation and available project documentation.
Browse the full archive01 / CUSTOM ELECTRONICS
Six actuators, sensor inputs, ESP32 control and battery management, brought together on a custom board.
View the project overviewLimited public overview02 / PCB design + embedded firmware
A two-board control system separates the operator’s keypad from the relay outputs. The handheld unit sends key events over CAN; the receiver maps each event to the corresponding relay.
Project detailsPCB and firmware development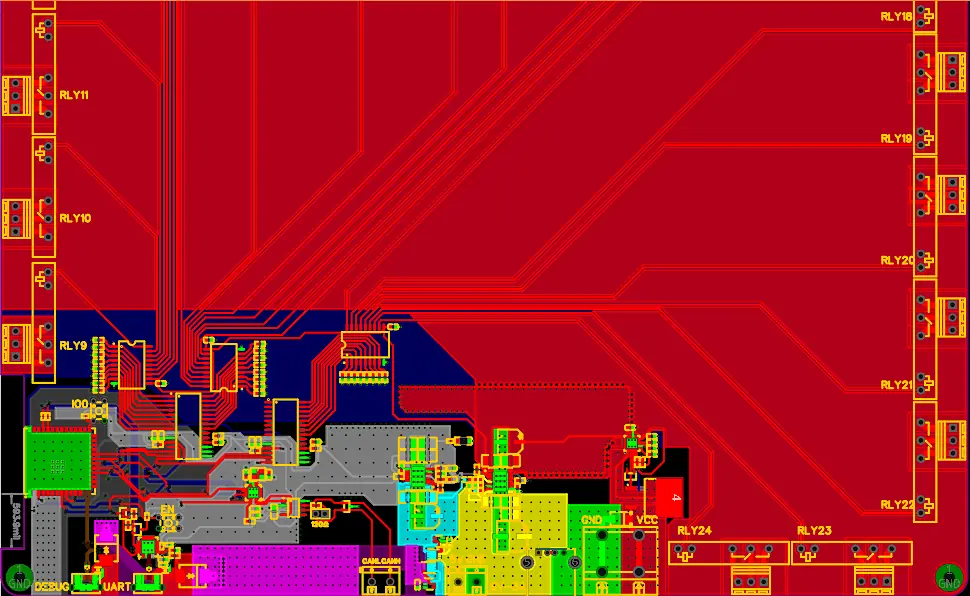
03 / Firmware + hardware integration
An ESP32 controls a large bingo display using WS2812 pixels. Wireless game updates select number highlights, with a pixel map linking each number to its panel position.
Project detailsFirmware and hardware integration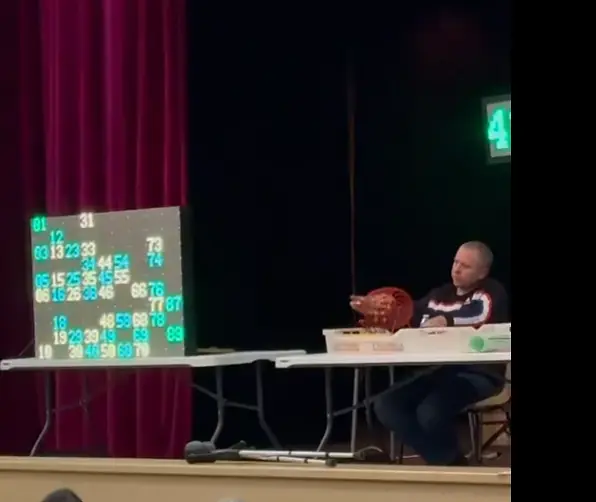
04 / Connected-device integration
The machine-control path moves browser commands over MQTT to an ESP32, while the existing Firebase services continue to handle accounts, balances, payments and session records.
Project detailsControl integration / camera work ongoing
05 / Firmware diagnosis + calibration
ATtiny84A firmware calibrates a replacement joystick for an N64 stick converter. The centre position and eight directional references define the usable travel and its mapping to the console’s expected output.
Project detailsDelivered firmware / follow-up refinementConceptual workflow
06 / Embedded telemetry + browser interface
Firmware and a browser interface for a radio-based race-tracking system. The work covers position and status packets, a LoRa-to-web gateway, map updates and GPX route logging.
Project detailsSystem development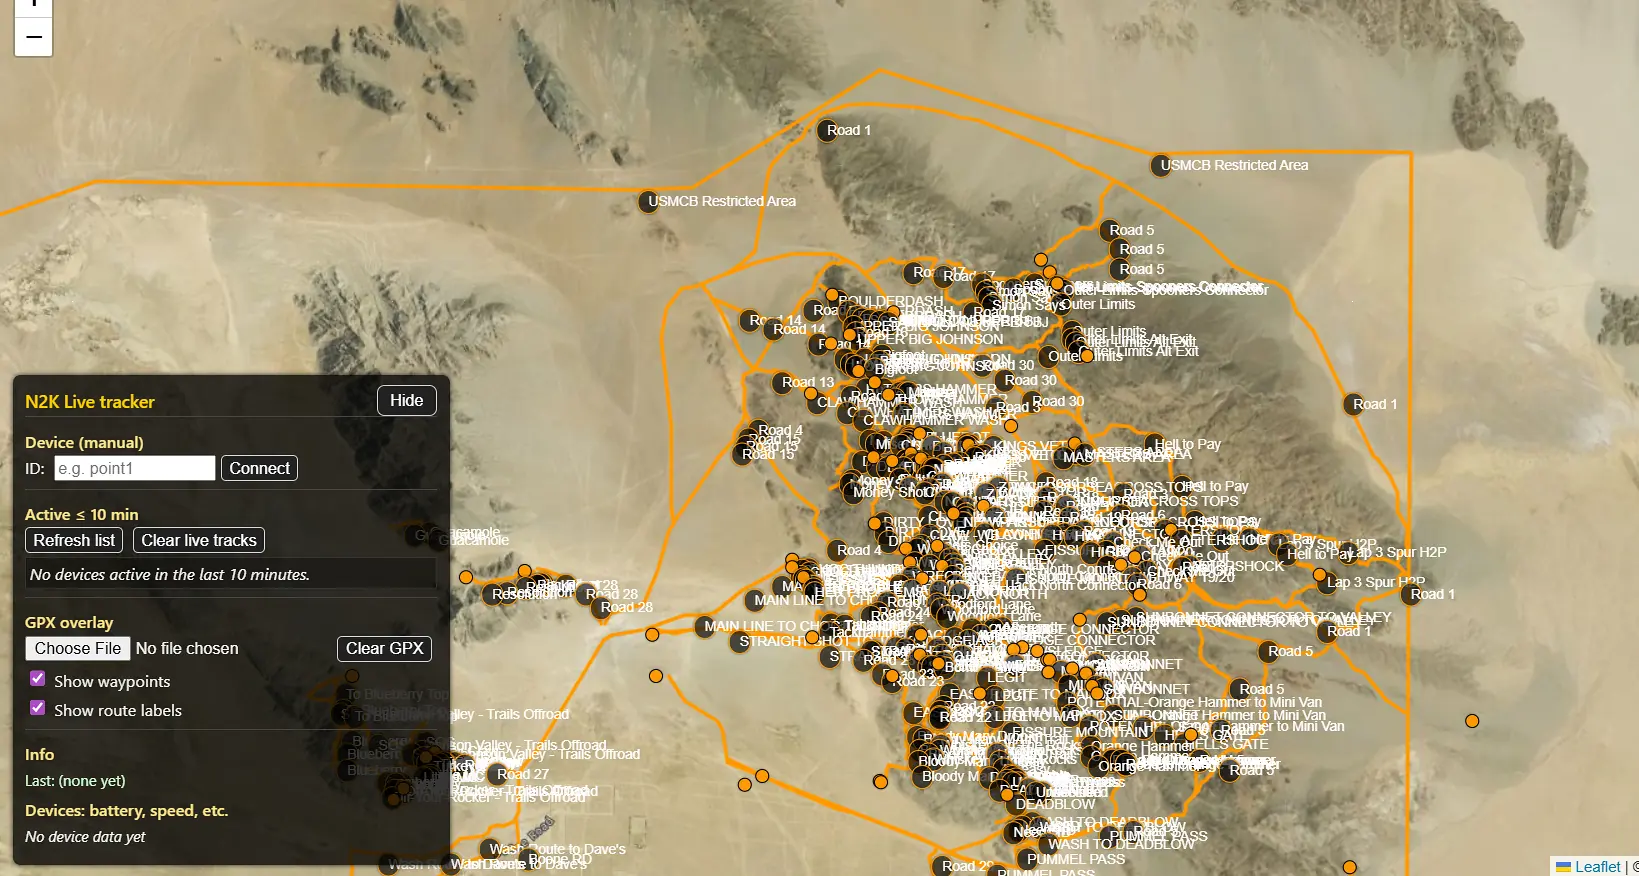
07 / PCB layout + design review
A restored car radio needs modern amplifier electronics within a fixed board outline. The design brings audio inputs, front and rear speaker connections, control signals and a vehicle supply into a 50 × 50 mm footprint.
Project detailsDesign and layout refinement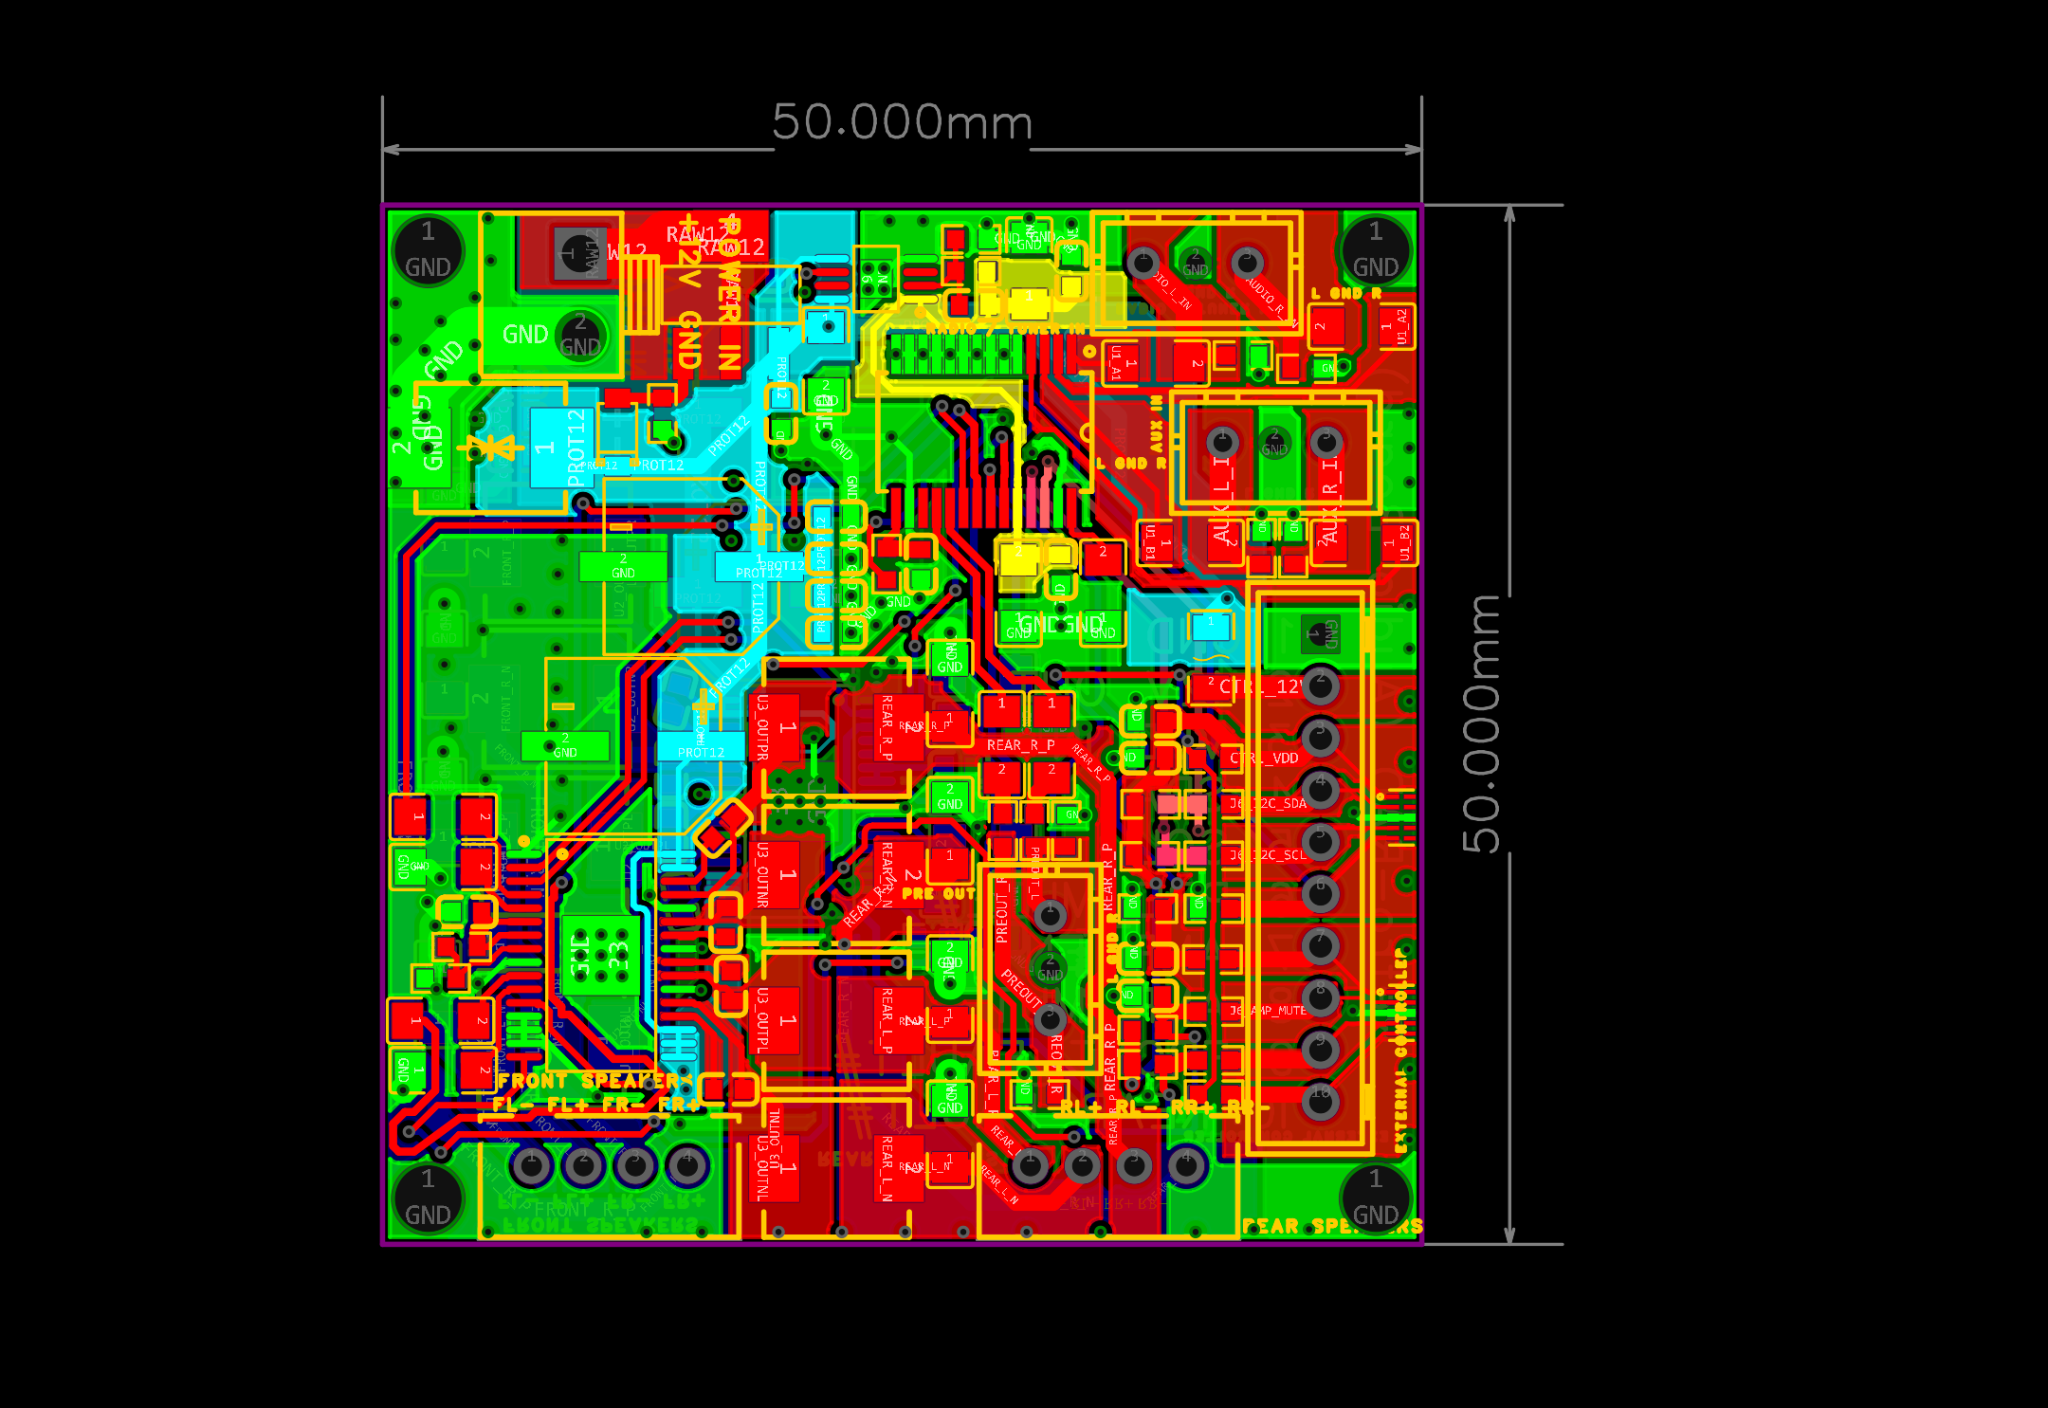
08 / Embedded firmware + prototype work
AbuLou SmartLED implements colour fades, stored scripts and motor patterns on an ATtiny85, controlled through a compact I2C command interface.
Project detailsFirmware and prototype work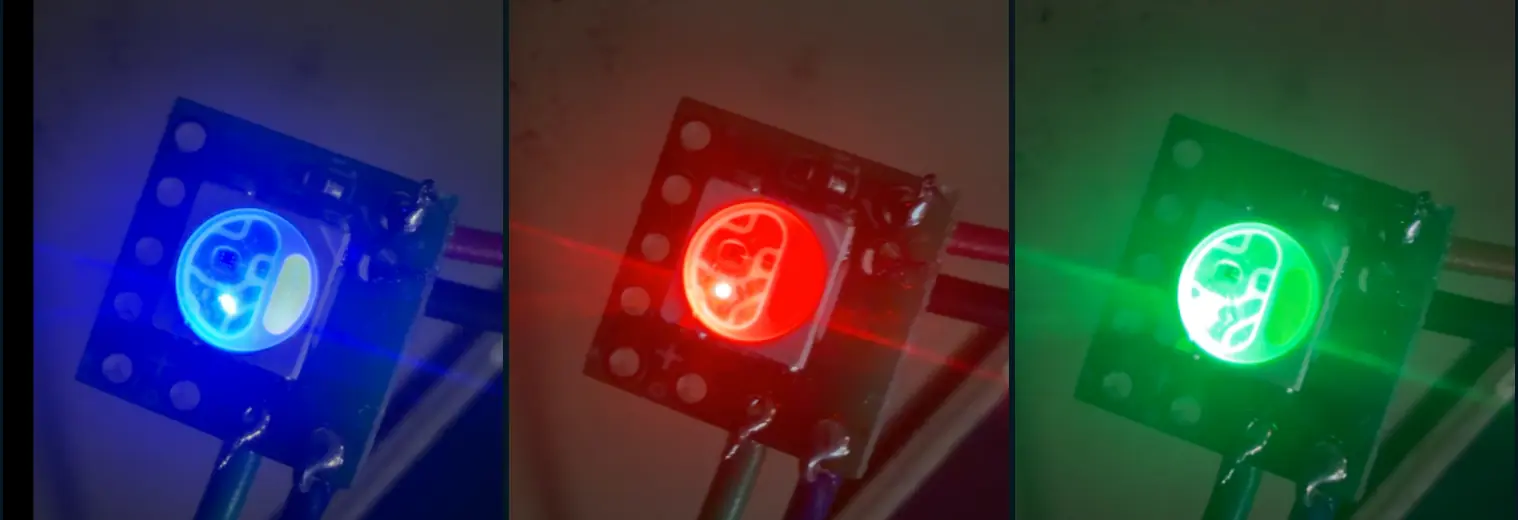
09 / Sensing + prototype firmware
A handheld target-alignment prototype combines IMU orientation with LiDAR range measurements. The firmware brings the two inputs into a consistent update sequence before producing feedback.
Project detailsPrototype firmware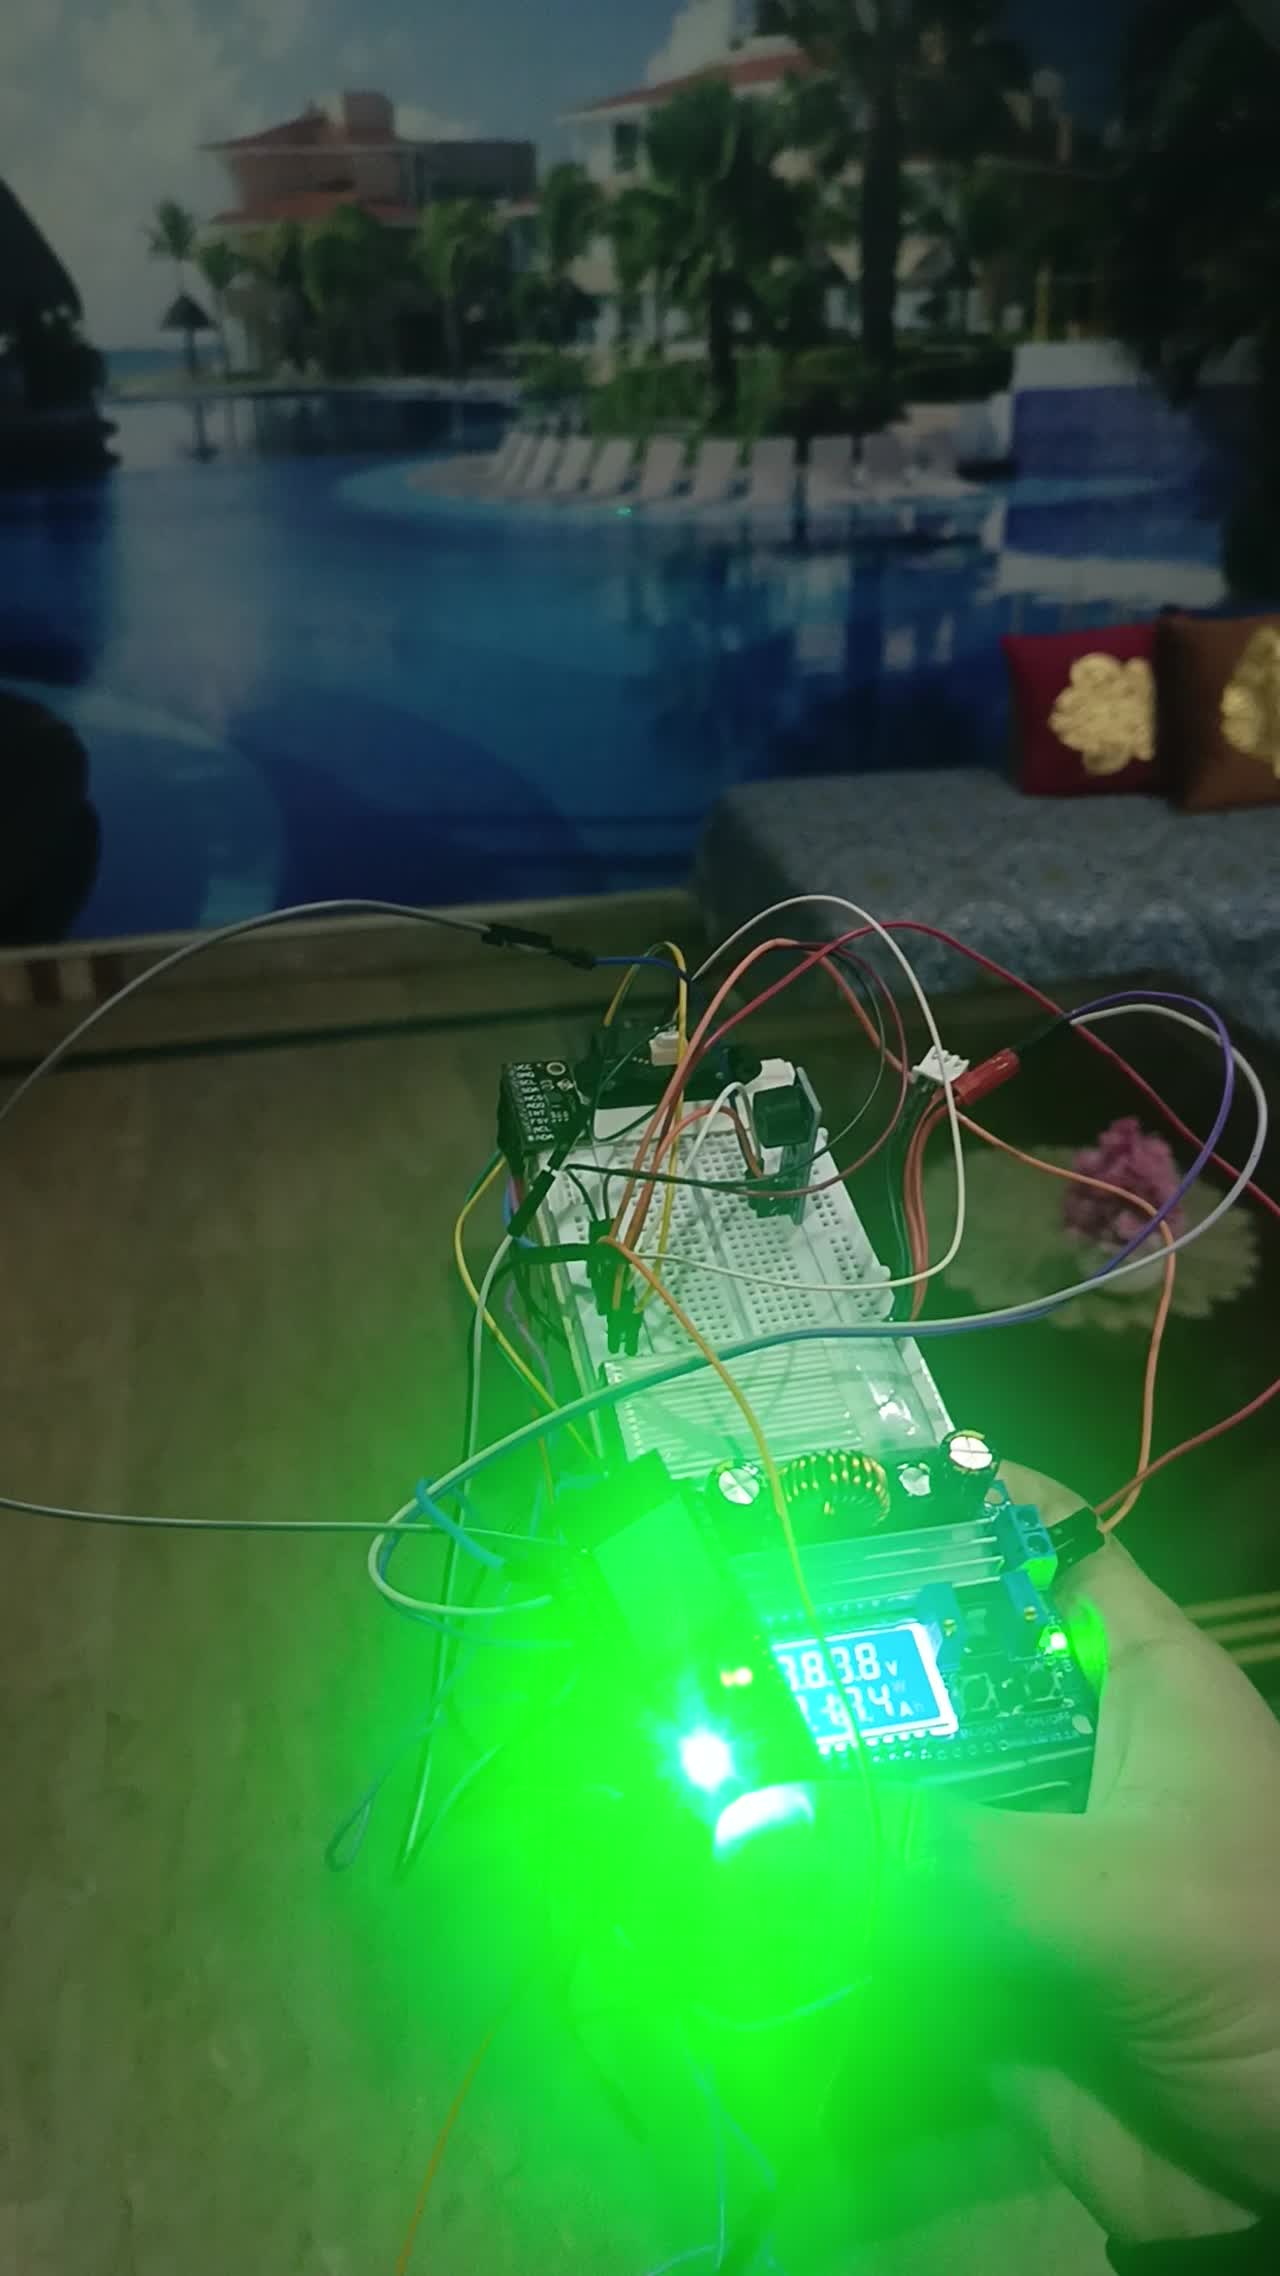
10 / PCB design
An RP2040 interface board combines controller connections, power and signal interfaces. Routing and assembly views document the component layout and connector placement.
Project detailsPCB design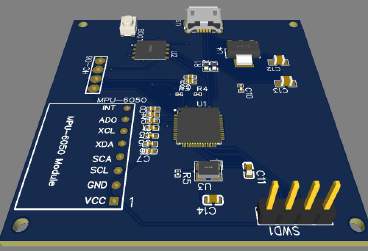
11 / Embedded sensing + wireless serial
A DHT11 sensor supplies temperature and humidity readings to a Bluetooth serial link. The firmware checks the measurements before formatting them for an HC-05 receiver.
Project detailsDevelopment work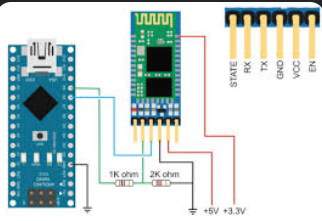
Prototype demonstration
Original recording of the stair-climbing robot prototype.
Project enquiries
Tell us what you’re developing and where you need engineering support.