Technical notes
Channel organisation
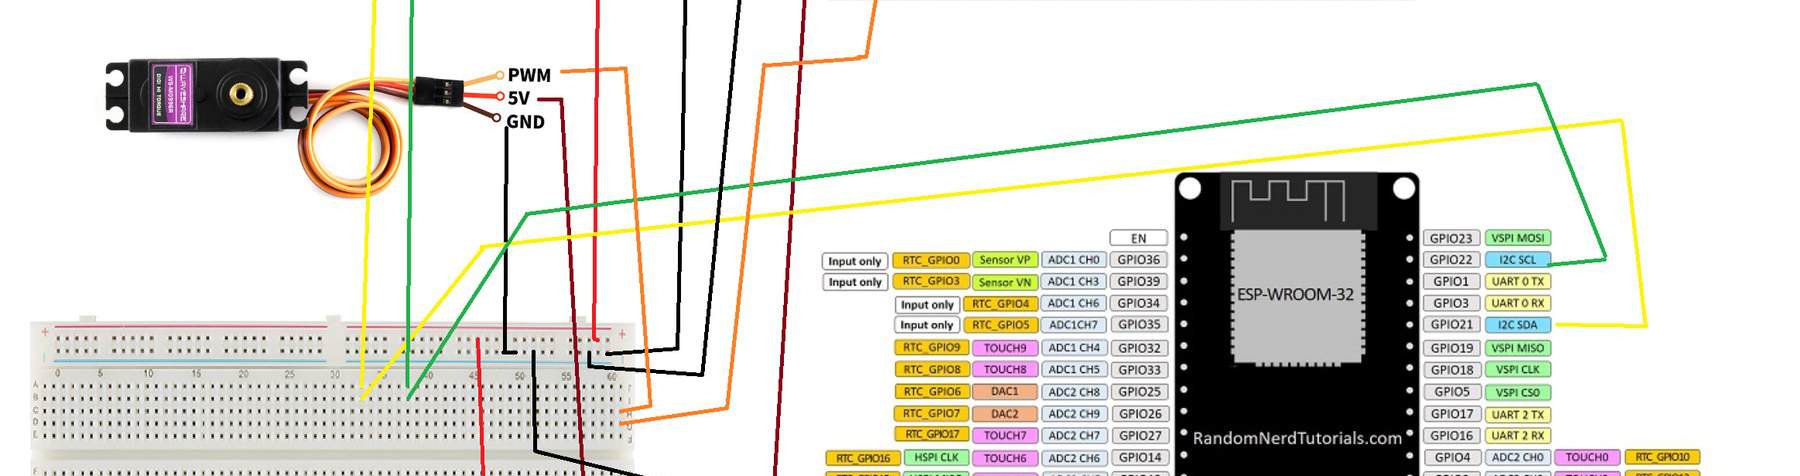
The PCA9685 forms the centre of the servo interface. A shared control connection lets the firmware address multiple outputs through a dedicated driver rather than treating each servo as a separate software interface.
Physical connections
The wiring illustration identifies the servo's signal, supply and ground connections beside an ESP32 pinout. This connects the software-facing interface to the wiring required at the actuator.
Command and power interfaces
Servo command handling and actuator power are related but separate concerns. Wiring documentation makes that distinction clear before assessing movement on the bench.