Documented architecture
Technical notes
CAN command input
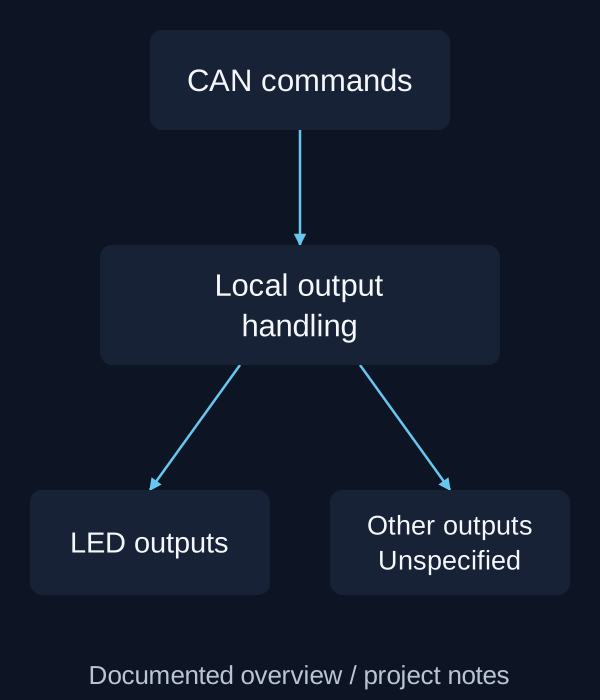
CAN commands are interpreted by the node’s output-control firmware.
Local output control
LED control is one of the output functions. The module also covers other output commands, linking the communication interface with local hardware control.
Bus-to-output integration
The module connects distributed CAN commands with the device’s local outputs.